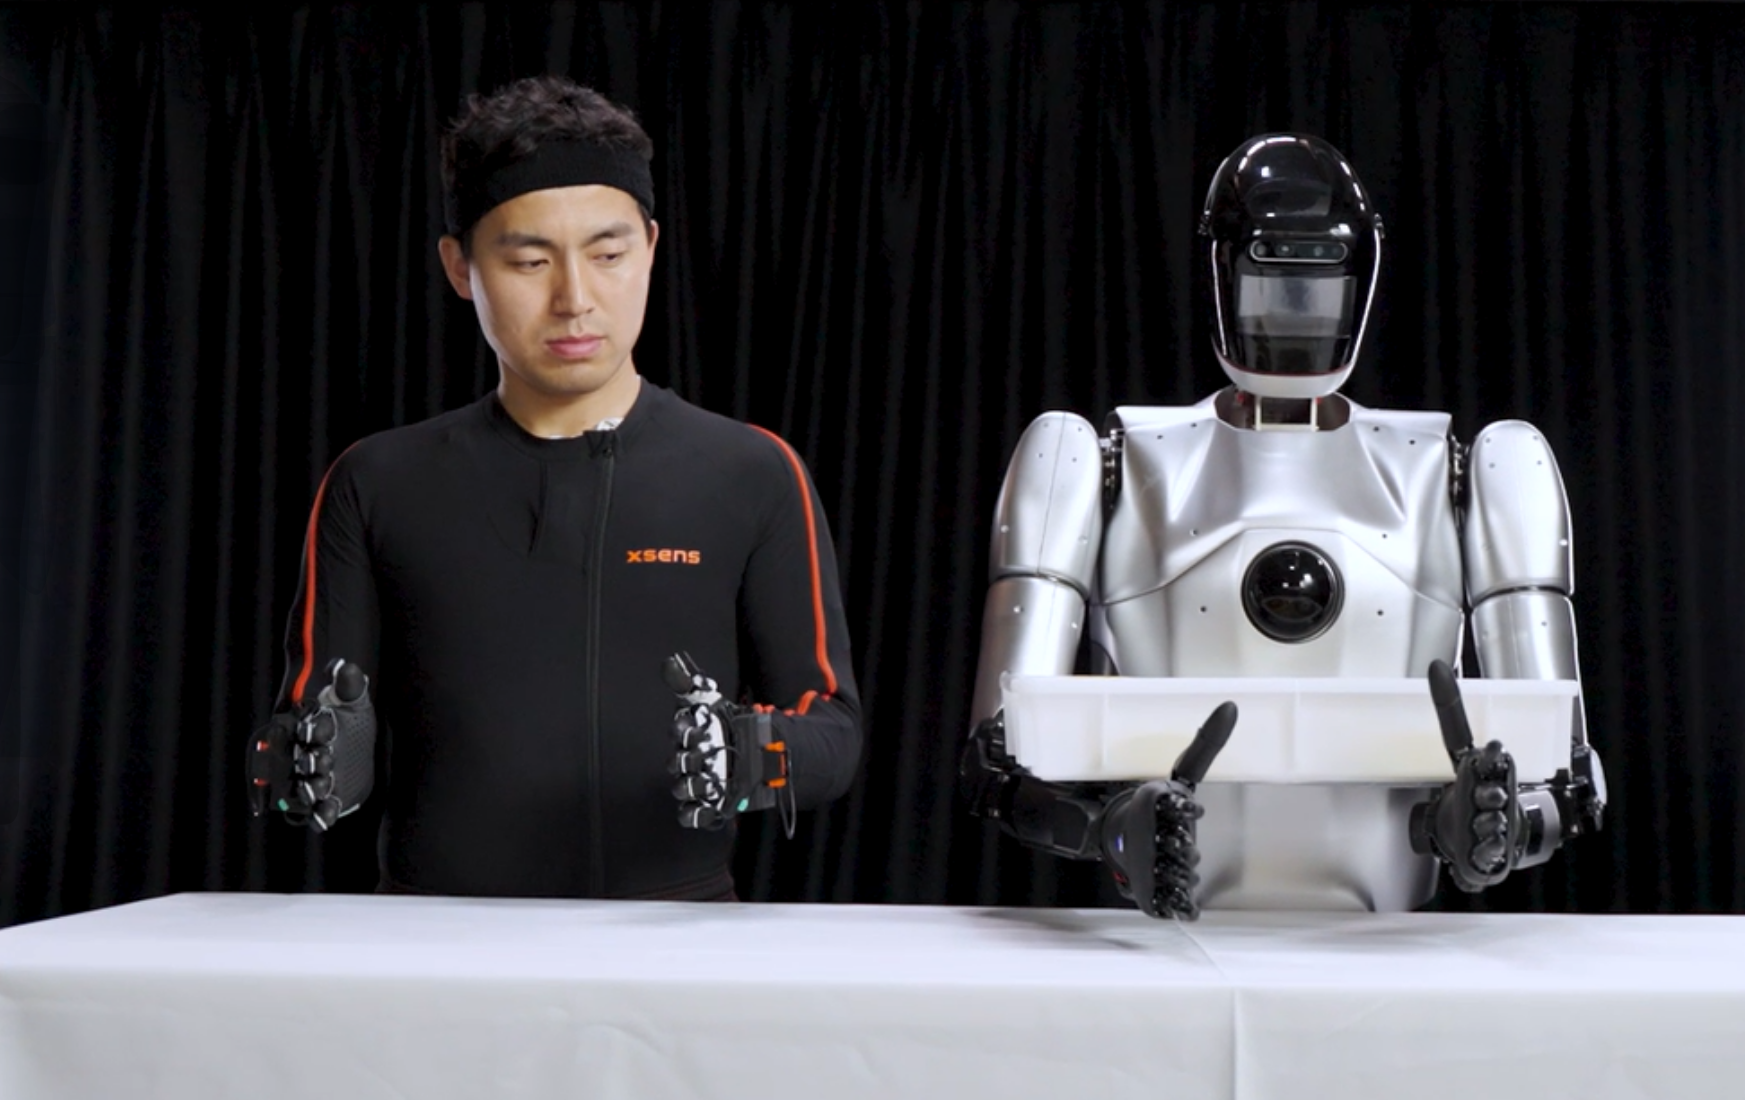
Humanoids need massive volumes of high-quality human movement data.
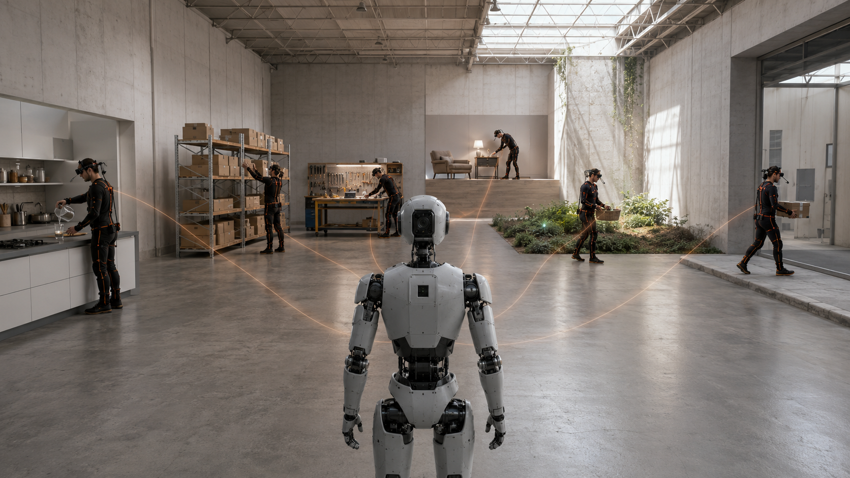
The challenge is not only capturing accurate data once. It is capturing it repeatedly and identically, in any environment, at the scale that training robots and automating work demand.
Human capture·Deployed
High Quality Deployable Data·At Scale
What Xsens-Humanoids can do for you
Train faster and deploy with confidence, on high-quality data you can capture anywhere.
Validated, multi-modal data, captured in any environment and repeatable across operators, sites and sessions, so your models generalize on real human movement and less (simulation) training hours.
Get started
What are you looking to achieve?
Collect data
Collect human data at scale
Build a data-collection operation, or digitize and roboticize your own workforce with repeatable, validated capture across operators, sites and tasks.
The Xsens platform grows with your humanoid program. Scalable from a single-system research pilot to a multi-site production data farm.
01 · Pilot
1-10 systems
Research & First Pilots
Validate feasibility. Prototype the teleop stack. Collect a seed dataset for first model training runs.
Lab-ready suits · Fast onboarding
02 · Scale
10-100 systems
Program Scale-Up
Multi-operator sessions, daily capture cycles, dedicated data spaces feeding model training and sim-to-real loops.
Orchestrated sessions · Repeatable quality
03 · WORKFORCE
100-1000 systems
Industrial Data Farming
Distributed data collection across facilities, operators and tasks. Collect data in the wild at high scale in any environment.
Fleet management · Data Collection as a Service
04 · ENTERPRISE
1000+ systems
Enterprise Fleet Operations
Deploy human motion capture across workforces, facilities and tasks. Turn real-world human expertise into continuous, high-quality data for robot training and automation at enterprise scale.
The cleanest ground-truth data humanoid teams can train on. Built from 25 years of inertial science. Validated by hundreds of universities. Patented at every layer.
HD Reprocessing Engine. Re-process recorded data offline for the best quality
Minimal drift. Holds quality across long captures and full-shift sessions.
Full 3D kinematic output. Every joint, every segment, every frame.
Full magnetic immunity. The only inertial mocap built to maintain high-quality data around metal, motors, and industrial machinery, where humanoid robots actually operate
High-fidelity foot contact. Ground-truth contact phase, not heel-toe approximation. The basis for stable balance, accurate Center of Pressure and Center of Mass, and the full kinetic chain resolved through the body.
Ready to scale your humanoid data program?
Talk to the team powering the motion data behind the next generation of humanoid robots.